
By : Rahimuddin
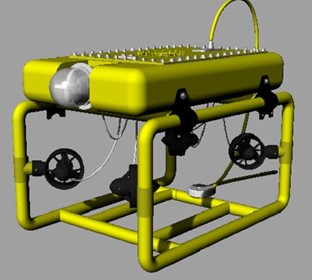
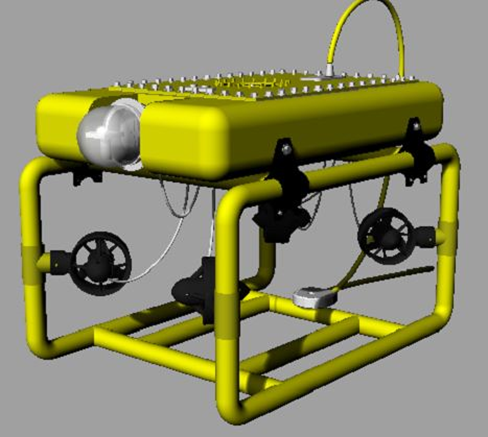
The underwater vehicle prototype, Remotely Operated Vehicle (ROV), is designed for underwater surveys and observations with omni-directional maneuvering capability. Measuring 58.6 cm in length, 42.21 cm in width, and 32.6 cm in height, and weighing 28.17 kg, the ROV is equipped with five propellers—four for horizontal movement and one for vertical movement—enabling it to move in all directions, including ascending, descending, side-to-side, and rotating. Operated via a joystick-based navigation system, the vehicle’s microcontroller manages sensor data and controls the propeller motors using PWM algorithms. Key components include an underwater camera for image capturing, LED lights for illumination, and sensors for pressure, temperature, and leakage detection. Stability is ensured by positioning the center of gravity below the center of buoyancy, allowing the vehicle to maintain balance even under external disturbances. An adjustable ballast system enhances flexibility in weight distribution, improving maneuverability and movement efficiency. Initial testing in a small pool demonstrated effective responsiveness to navigation commands, including maneuvers and drift movements, with subsequent modifications to the propellers and waterproofing system for improved performance. Powered by a surface station and onboard batteries, the prototype is designed for extended operations, with future development focusing on refining electronic systems, larger-scale testing, and integrating the camera system with an operator interface.
Link paper terkait:
Paper1: https://iopscience.iop.org/article/10.1088/1742-6596/962/1/012017/pdf
Paper2: https://iopscience.iop.org/article/10.1088/1757-899X/619/1/012048/pdf