By : Muhammad Abdillah & Rahimuddin
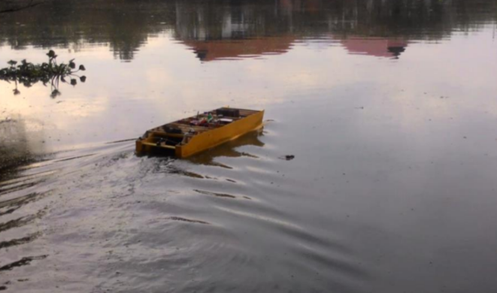
This study aimed to design an autopilot system for a semi-swath ship, integrating an Ardupilot microcontroller, GPS, and PID control method. The system was tested on circular and zig-zag routes. Results demonstrated effective navigation with optimal PID values (Kp=1.15K_p=1.15Kp=1.15, Ki=0K_i=0Ki=0, Kd=8.5K_d=8.5Kd=8.5), achieving minimal GPS error (average 0.35m for circular paths). This highlights the system’s precision in controlling pitch, roll, and yaw during navigation.