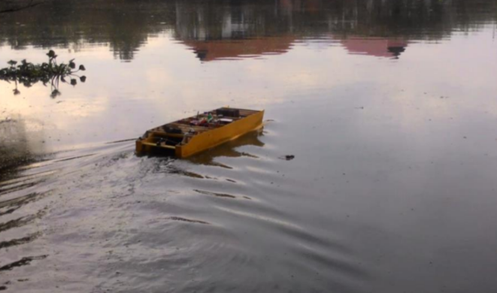
Speed Control of Autopilot Ship Using PID Method

By : Zul Syahril & Rahimuddin

This research aims to design and evaluate a speed control system for autopilot ships using the PID (Proportional-Integral-Derivative) method. The system adjusts speed based on GPS data using trial-and-error-tuned PID parameters: Kp=6, Ki=1, and Kd=0.5. The results demonstrated steady-state error of 0.4% and a settling time of 8.5 seconds, ensuring effective and precise speed control.
Leave a Reply

Your email address will not be published. Required fields are marked *

Ir. Muhammad Alief Fahdal Imran Oemar,Β ST.,Β M.Sc

 Muhammad Alief Fahdal Imran Oemar is an academic from Hasanuddin University with a bachelor’s degree in Informatics Engineering. He has an overall SINTA score of 110, with a score of 84 in the last three years. His scientific contributions include various publications, such as “Information System and Village Management to Improve the Regional Economy and Community Productivity” and “Digitalization of MSMEs to Build a Digital Ecosystem for MSME Communities in Sulawesi.” These works reflect his dedication to applying information technology for community empowerment and regional economic development.